
let’s take a deep dive into robot mechanics and electronics. in this series; i will break down a packbot 510 series explorer chassis. this is old tech at this point; but good source of inspiration for builders and makers. 1/12


2/12 basic disassembly starts with the front flippers. these are power adjustable and give the robot its stair climbing ability. they are driven by the main track system.


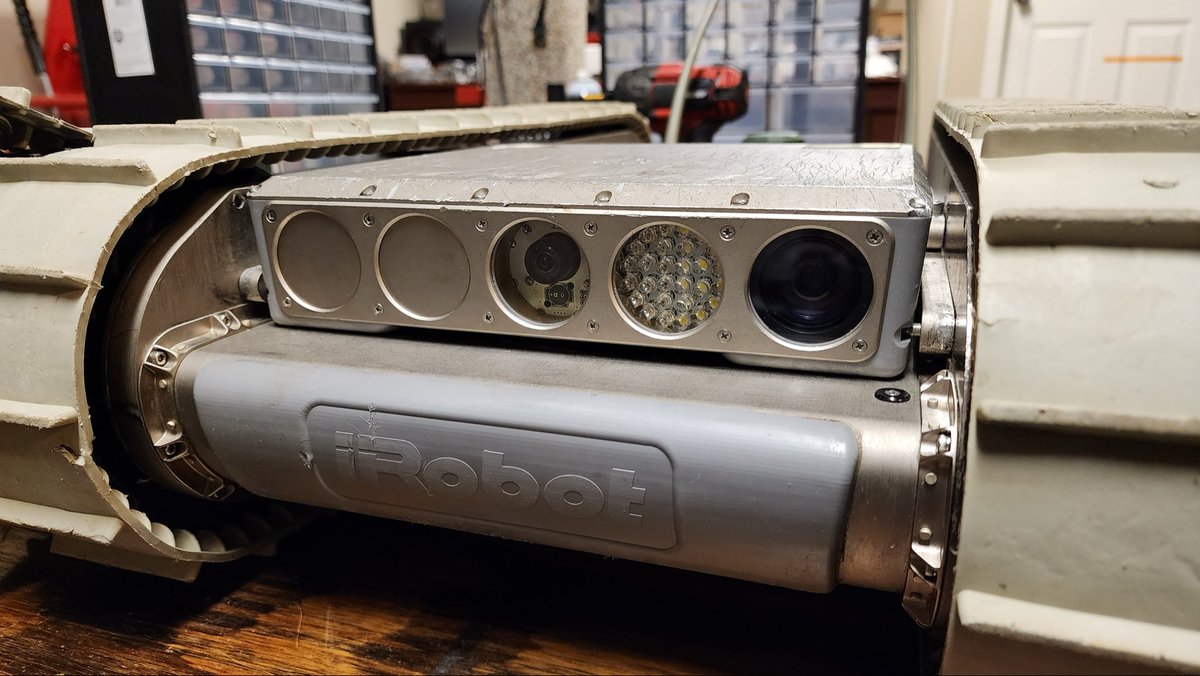
3/12 inside of the explorer payload; contains the 30x optical zoom camera, wide angle drive camera and lighting. you’ll see a spot on the board for the optional flir thermal camera.


4/12 payload removed; chassis tear down begins. interesting to note that the batteries are placed inside of the track assemblies. there’s a pcb inside of each side rail that transfers power/data down the chassis.


5/12 some pics of the main drive assembly before further tear down. if you look closely; you can see one of the main drive gears for the track assemblies.


6/12 inside the chassis you’ll find a 3d pcb assembly. drive motors and flipper motor attached to the pcba. also the park brake mechanism is part of the pcba; more on that in the next post.


@Alpha10six The green knob is a very robust GPS antenna?
@Alpha10six Holy shit, the algo is working. This is exactly the kind of content I am after
@Alpha10six The dashboard is so sick
@ZachSents it is pretty dope haha